Navigate
Robust robot navigation is a cornerstone for application domains such as Social Care, Logistics and Manufacturing, where productivity often requires mobile manipulation. In Service & Inspection robotics, in particular, understanding surroundings - in terms of location and circumstance - is a prerequisite for autonomy. This theme examines how unusual sensors, novel processing, and new perspectives on cross-modal mapping and localisation can improve performance and endurance of machines with embodied intelligence. We focus on developing the algorithmic techniques required for minimally supervised, long-term autonomy providing robust and efficient navigation capability
across the whole gamut of deployment scenarios - from factory floors and care homes to vast, unstructured, challenging environments.
Depth-SIMS: semi-parametric image and depth synthesis
Musat V, De Martini D, Gadd M, Newman P
2022 International Conference on Robotics and Automation (ICRA)
In this paper we present a compositing image synthesis method that generates RGB canvases with well aligned segmentation maps and sparse depth maps, coupled with an in-painting network that transforms the RGB canvases into high quality RGB images and the sparse depth maps into pixel-wise dense depth maps.
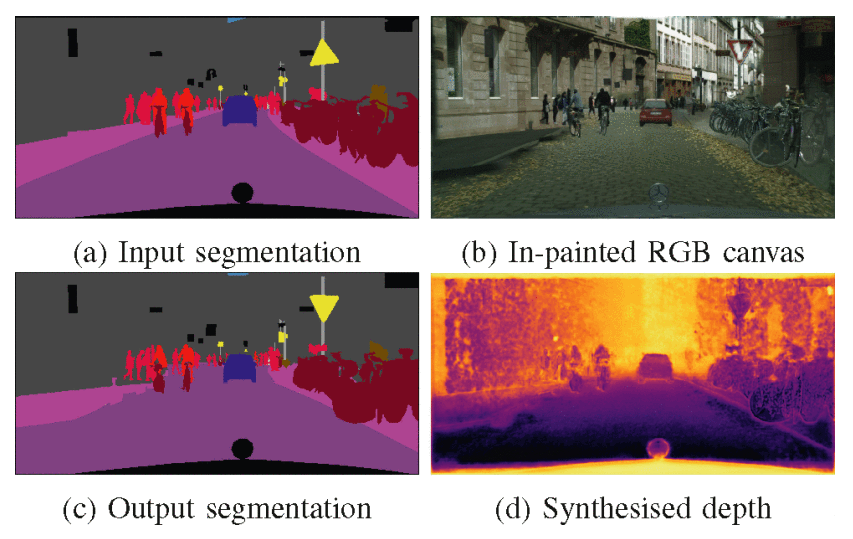
We benchmark our method in terms of structural alignment and image quality, showing an increase in mIoU over SOTA by 3.7 percentage points and a highly competitive FID. Furthermore, we analyse the quality of the generated data as training data for semantic segmentation and depth completion, and show that our approach is more suited for this purpose than other methods.
BoxGraph: semantic place recognition and pose estimation from 3D LiDAR
Pramatarov G, De Martini D, Gadd M, Newman P
2022 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
This paper is about extremely robust and lightweight localisation using LiDAR point clouds based on instance segmentation and graph matching. We model 3D point clouds as fully-connected graphs of semantically identified components where each vertex corresponds to an object instance and encodes its shape.
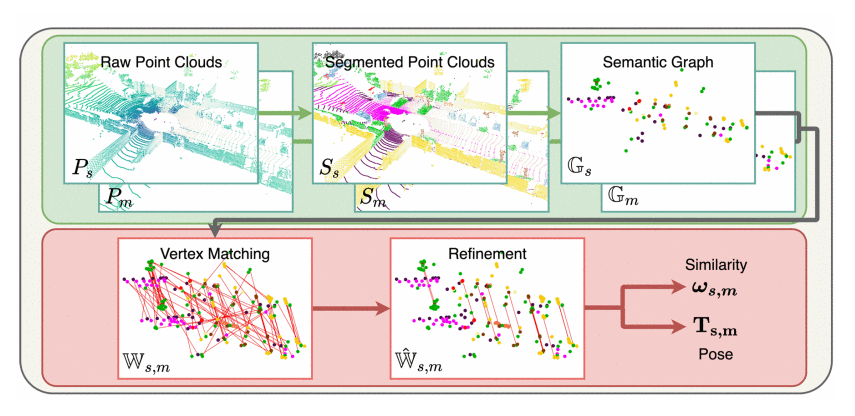
Optimal vertex association across graphs allows for full 6-Degree-of-Freedom (DoF) pose estimation and place recognition by measuring similarity. This representation is very concise, condensing the size of maps by a factor of 25 against the state-of-the-art, requiring only 3 kB to represent a 1.4 MB laser scan. We verify the efficacy of our system on the SemanticKITTI dataset, where we achieve a new state-of-the-art in place recognition, with an average of 88.4 % recall at 100 % precision where the next closest competitor follows with 64.9 %. We also show accurate metric pose estimation performance - estimating 6-DoF pose with median errors of 10cm and 0.33 deg.
Other related publications
Explainable Action Prediction through Self-Supervision on Scene Graphs
Kochakarn P, De Martini D, Omeiza D, Kunze L
Journal: Journal of Machine Learning Research Volume: 23 Issue:151
Look Here: Learning Geometrically Consistent Refinement of Inverse-Depth Images for 3D Reconstruction
Săftescu S, Gadd M, and Newman PJournal: 15th International Conference on Computer Vision Theory and Applications (VISAPP 2020)
Point-based metric and topological localisation between lidar and overhead imagery
Tang T, De Martini D & Newman P
Journal: Autonomous Robots (2023)
Fast-MbyM: leveraging translational invariance of the fourier transform for efficient
Weston R, Gadd M, De Martini D, Newman P, Posner I
Journal: Proceedings of the IEEE International Conference on Robotics and Automation (ICRA 2022)
What goes around: leveraging a constant-curvature motion constraint in radar odometry
Aldera R, Gadd M, De Martini D, Newman P
Journal: IEEE Robotics and Automation Letters 2022
The Oxford Road Boundaries Dataset
Suleymanov T, Gadd M, De Martini D, Newman P
Journal: 2021 IEEE Intelligent Vehicles Symposium Workshops (IV Workshops)
Contrastive learning for unsupervised radar place recognition
Gadd M, De Martini D, Newman P
Journal: 2021 20th International Conference on Advanced Robotics (ICAR)
Fool me once: robust selective segmentation via out-of-distribution detection with co
Williams D, Gadd M, De Martini D, Newman P
Journal: 2021 IEEE International Conference on Robotics and Automation (ICRA)
RSS-Net: weakly-supervised multi-class semantic segmentation with FMCW radar
Kaul P, De Martini D, Gadd M, Newman P
Journal: Proceedings of the 2020 IEEE Intelligent Vehicles Symposium (IV2020)
kRadar++: coarse-to-fine FMCW scanning radar localisation
De Martini D, Gadd M, Newman P
Journal: Sensors Volume:20 Issue:21